Realtek RTL8730E-EVB
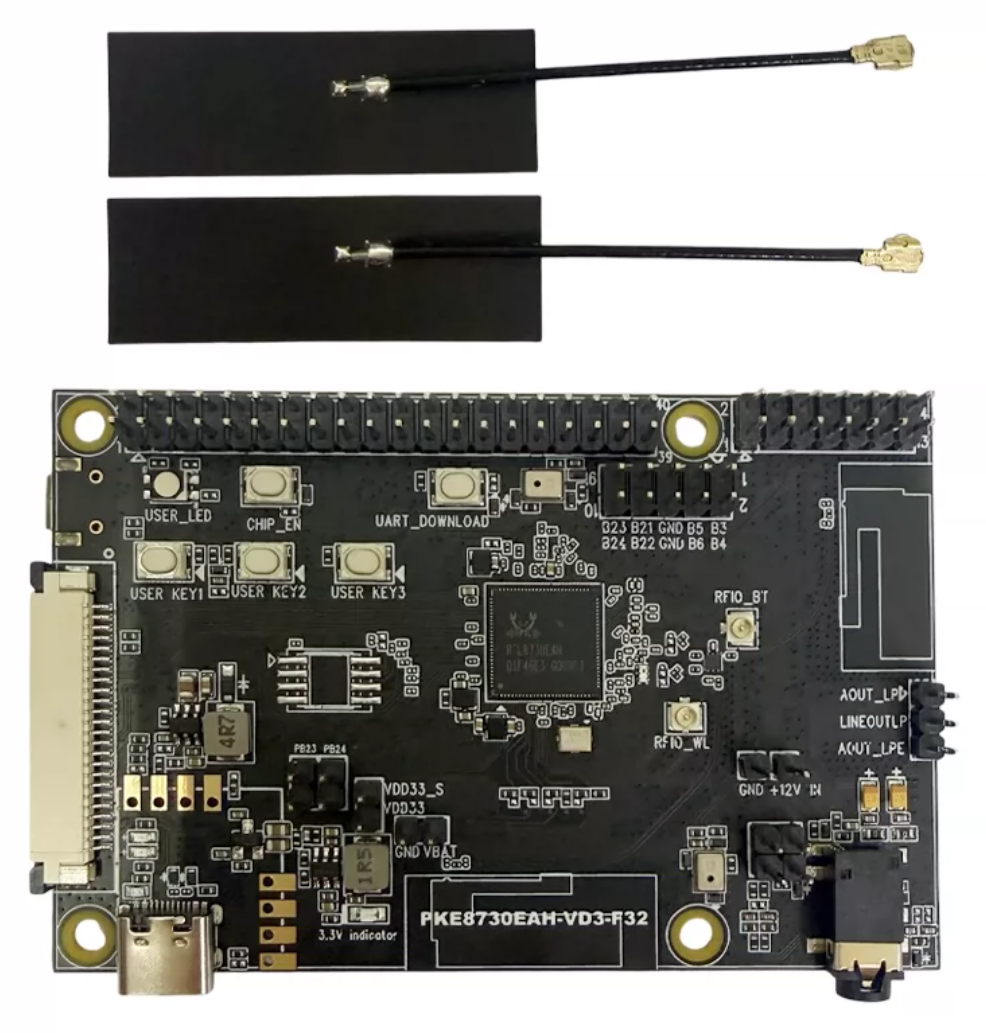
The RTL8730E EVB development board.
The RTL8730E_EVB is a Realtek RTL8730E evaluation board built around the RTL8730EH (DDR2 64 MB, 16 MB NOR flash). NuttX runs on the dual-core Arm Cortex-A32 application processor at up to 1.2 GHz as BL33 in the ATF boot chain. See the RTL8730E chip documentation for the full SoC specifications and vendor-SDK dependency.
Features
RTL8730EH: dual-core Arm Cortex-A32 up to 1.2 GHz, 64 MB DDR2, 16 MB NOR flash
Symmetric Multi-Processing (SMP) on both Cortex-A32 cores
Wi-Fi 6 (802.11ax) dual-band (2.4 / 5 GHz) station and SoftAP
Bluetooth 5 dual-mode (BR/EDR + LE)
SPI NOR flash with littlefs at
/dataLOG-UART console at 1500000 8N1
Supported in this NuttX port:
NSH shell over the LOG-UART console
SMP on both Cortex-A32 cores; tasks are dispatched across CPU0 and CPU1 by the NuttX SMP scheduler
GPIO pins exposed as
/dev/gpioNcharacter devices (input, output and interrupt), driven through the SDK fwlib ROM layerGeneral-purpose UARTs exposed as
/dev/ttySNserial devices, driven through the SDK fwlib ROM layer (the LOG-UART owns the console and/dev/ttyS0)I2C master buses exposed as
/dev/i2cNcharacter devices, driven in polling mode through the SDK fwlib register layerSPI master buses exposed as
/dev/spiNcharacter devices, driven in polling mode through the SDK fwlib register layerPWM output exposed as a
/dev/pwm0character device, driven directly on the SDK fwlib timer layerGeneral-purpose timers exposed as
/dev/timerNcharacter devices, with microsecond timeouts and a periodic expiration callbackOn-chip watchdog exposed as a
/dev/watchdog0character device12-bit ADC exposed as a
/dev/adc0character device, sampled in polling mode through the SDK fwlib register layerOn-chip RTC exposed as a
/dev/rtc0character device, with a one-shot alarmlittlefs persistent storage mounted at
/data(a dedicated SPI NOR flash partition), backing the Wi-Fi key-value storeWi-Fi station and SoftAP through the
wapitoolDHCP client (STA) and DHCP server (SoftAP)
/etcread-only ROMFS populated from the board’ssrc/etc/tree
Configurations
Build and flash any of these per the RTL8730E build instructions.
$ ./tools/configure.sh rtl8730e_evb:<config-name>
nsh
Networking-enabled NSH with SMP, littlefs at /data, and the wapi
Wi-Fi tool. The console is the LOG-UART at 1500000 8N1.
gpio
Minimal NSH with the GPIO driver and the gpio example enabled (no Wi-Fi).
The board registers three pins from its pin table (see
boards/arm/rtl8730e/rtl8730e_evb/src/rtl8730e_gpio.c): an output at
/dev/gpio0, an input at /dev/gpio1 and an interrupt pin at
/dev/gpio2. Edit that table to match a board’s wiring. Exercise them
with the example:
nsh> gpio -o 1 /dev/gpio0     # drive the output high
nsh> gpio /dev/gpio1          # read the input
nsh> gpio -w 1 /dev/gpio2     # wait for a falling-edge interrupt
Pins are encoded with the AMEBA_PA() / AMEBA_PB() helpers from
arch/arm/src/common/ameba/ameba_gpio.h (port A/B, pin 0-31), matching the
Ameba SDK PinName layout.
uart
Minimal NSH with the general-purpose UART driver and the serialrx /
serialblaster examples enabled (no Wi-Fi). The LOG-UART owns the console
and /dev/ttyS0, so the board registers UART0-2 from its table (see
boards/arm/rtl8730e/rtl8730e_evb/src/rtl8730e_uart.c) as /dev/ttyS1-3
at 115200 8N1. Edit that table – controller, TX/RX pads and baud – to match a
board’s wiring. The TX/RX pads use the same AMEBA_PA() / AMEBA_PB()
encoding as the GPIO table; the driver muxes them to the UART function and
pulls RX high through the SDK ROM. Exercise a port with the examples (loop TX
back to RX, or wire it to a host serial adapter):
nsh> serialblaster /dev/ttyS1 26   # stream a test pattern out /dev/ttyS1
nsh> serialrx      /dev/ttyS1 26   # receive and dump bytes from /dev/ttyS1
The line format can be changed at runtime through tcsetattr() (the config
enables CONFIG_SERIAL_TERMIOS). UART3 is reserved for Bluetooth and is not
exposed by the driver.
i2c
Minimal NSH with the I2C master driver and the i2ctool (system/i2c)
enabled (no Wi-Fi). The board registers its I2C controllers from a table (see
boards/arm/rtl8730e/rtl8730e_evb/src/rtl8730e_i2c.c): I2C0 at
/dev/i2c0 on PA10/PA9, I2C1 at /dev/i2c1 on PA4/PA3 and I2C2 at
/dev/i2c2 on PB11/PB10 (SCL/SDA). Edit that table – controller and
SCL/SDA pads – to match a board’s wiring; the pads use the same
AMEBA_PA() / AMEBA_PB() encoding as the GPIO table and are muxed to
the I2C function through the SDK ROM. Unlike the GPIO and UART crossbars, a
pad reaches exactly one I2C controller, and pads the audio codec drives
cannot be used. The I2C bus is open-drain, so fit external pull-ups on
SCL/SDA. Probe a bus with the tool:
nsh> i2c dev -b 0 0x03 0x77 # scan /dev/i2c0 for devices
spi
Minimal NSH with the SPI master driver and the spi tool (system/spi)
enabled (no Wi-Fi). The board registers two buses from its table (see
boards/arm/rtl8730e/rtl8730e_evb/src/rtl8730e_spi.c): SPI0 at
/dev/spi0 with CLK/MOSI/MISO/CS on PB18/PB19/PB20/PB21 and SPI1 at
/dev/spi1 on PA11/PA9/PA10/PA12. The pads use the same AMEBA_PA() /
AMEBA_PB() encoding as the GPIO table and are muxed to the SPI function
through the SDK ROM, while the chip-select is driven as a plain GPIO. As with
I2C – and unlike the GPIO and UART crossbars – a pad reaches exactly one
controller, so edit that table within each controller’s own set: PB18-PB21
for SPI0, PB25-PB28 or PA9-PA12 for SPI1. Pads the audio codec drives cannot
be used. Exercise a bus with the tool:
nsh> spi exch -b 0 -x 4 deadbeef # full-duplex transfer on /dev/spi0
pwm
Minimal NSH with the PWM driver and the pwm example (examples/pwm)
enabled (no Wi-Fi). The board registers one timer at /dev/pwm0 (see
boards/arm/rtl8730e/rtl8730e_evb/src/rtl8730e_pwm.c): TIM8 drives six
compare channels off one shared time base, so every channel shares one
frequency and each carries its own duty cycle. The table routes the channels
to PA7/PA9/PA10/PA4/PA5/PA6. Despite the chip having a single
PINMUX_FUNCTION_PWM code, each pad is tied to one channel – the pin-mux
table names a pad’s PWM function HS_PWM<n>, which is channel n + 1 – so
an entry may only be cleared to AMEBA_PWM_PIN_NC or swapped for another
pad carrying the same HS_PWM<n>; PB14-PB16 are the alternative for
channels 1-3. Avoid PA14/PA13, which are SWD_CLK/SWD_DATA and stay muxed to
the debug port unless the board calls Pinmux_Swdoff(). Set
CONFIG_PWM_NCHANNELS to the number of channels used. Exercise it with the
example:
nsh> pwm -d 25 -f 1000 # 1 kHz, 25% duty on /dev/pwm0
timer
Minimal NSH with the timer driver and the timer example
(examples/timer) enabled (no Wi-Fi). The board registers two timers (see
boards/arm/rtl8730e/rtl8730e_evb/src/rtl8730e_timer.c): /dev/timer0
is TIM2 and /dev/timer1 is TIM3, both 32-bit LP basic timers clocked at
32.768 kHz, so a tick is ~30.5 us and a single timeout reaches ~36 hours.
Neither has any board wiring. TIM0 and TIM1 are not exposed: the ROM claims
TIM0 as the system timer behind DelayUs()/SYSTIMER_*, and the vendor
HAL claims TIM1 as its application and UART-timeout timer. Exercise a timer
with the example:
nsh> timer # 20 samples 0.1 s apart, 1 s timeout, on /dev/timer0
wdg
Minimal NSH with the watchdog driver and the wdog example (no Wi-Fi).
The board registers the on-chip watchdog at /dev/watchdog0 (see
boards/arm/rtl8730e/rtl8730e_evb/src/rtl8730e_wdg.c): WDG4, the CA32
non-secure system watchdog. It has no board wiring (it is an internal
timer) and, once enabled, cannot be stopped by software – the stop()
operation instead arms the early-interrupt and refreshes the counter from
its handler to inhibit the reset. Exercise it with the example, which
opens the device, sets a timeout, and pings it:
nsh> wdog # run the watchdog example on /dev/watchdog0
adc
Minimal NSH with the ADC driver and the adc example (examples/adc)
enabled (no Wi-Fi). The board registers one converter at /dev/adc0 (see
boards/arm/rtl8730e/rtl8730e_evb/src/rtl8730e_adc.c) listing CH2-CH5,
which each ANIOC_TRIGGER samples in list order. The chip has ten
channels; CH0-CH5 are external and bound to the fixed pads PA0-PA5 (the
pin-mux table names them TOUCHn_ADCn), while the rest are internal and
have no pad. PA0 and PA1 are not bonded out on the RTL8730EAM/EAH packages,
so the table leaves CH0 and CH1 out. The pads reach the converter through
the cap-touch function (PINMUX_FUNCTION_CAPTOUCH, function 18), shared
with the cap-touch controller and, on PA2-PA5, the DMIC, so those functions
cannot be used on the same pad. PA3/PA4 are also I2C1 pads and PA4/PA5 are
UART1 or PWM pads: a config that registers one of those too must drop the
clashing channel from the table. The input range is 0 to 3.3 V with 12-bit
samples, reported as raw codes. Exercise it with the example:
nsh> adc -n 1 # sample CH2-CH5 once on /dev/adc0
rtc
Minimal NSH with the RTC driver and the alarm example
(examples/alarm) enabled (no Wi-Fi). The board registers the on-chip RTC
at /dev/rtc0 (see boards/arm/rtl8730e/rtl8730e_evb/src/rtl8730e_rtc.c)
and the system time is seeded from it at boot. The RTC has no board wiring
(it is an internal clock in the always-on domain). The hardware keeps only a
year and a day-of-year, so the driver converts to and from calendar
month/day in software. After a cold power-up the counter starts in 1900; the
driver then seeds it with CONFIG_START_YEAR/MONTH/DAY, while a warm
RTC that already holds a later date is left alone. The RTC is reset by
CHIP_EN, power-on and system reset (which the board reset button
triggers), but not by BOR, thermal, deep-sleep or watchdog resets. After a
reset button press the registers therefore read back as zero (year 1900)
when the driver starts and the clock is seeded again, whereas after a
watchdog reset the time carries on. Exercise it with date and the alarm example:
nsh> date -s "Oct 28 12:00:00 2026"
nsh> date
nsh> alarm 5      # one-shot alarm on /dev/rtc0 firing in 5 seconds
Wi-Fi
Station (connect to an AP):
nsh> wapi mode  wlan0 2
nsh> wapi psk   wlan0 <password> 3
nsh> wapi essid wlan0 <ssid> 1
nsh> renew wlan0
SoftAP (become an access point, with a DHCP server for clients):
nsh> wapi mode   wlan0 3
nsh> wapi psk    wlan0 <password> 3
nsh> wapi essid  wlan0 <ssid> 1
nsh> dhcpd_start wlan0
Stop the SoftAP with wapi essid wlan0 <ssid> 0.
License Exceptions
This board depends on Realtek vendor code that is not part of NuttX and is subject to its own license:
The prebuilt Wi-Fi / Bluetooth firmware image and the Realtek
ameba-rtosSDK libraries/headers linked into the image. See the SDK’s own license; the SDK is auto-fetched and is not redistributed in the NuttX tree.The prebuilt ATF BL2 and BL32 binaries under
prebuilt/are provided by Realtek and are subject to the Realtek binary license included in the SDK.